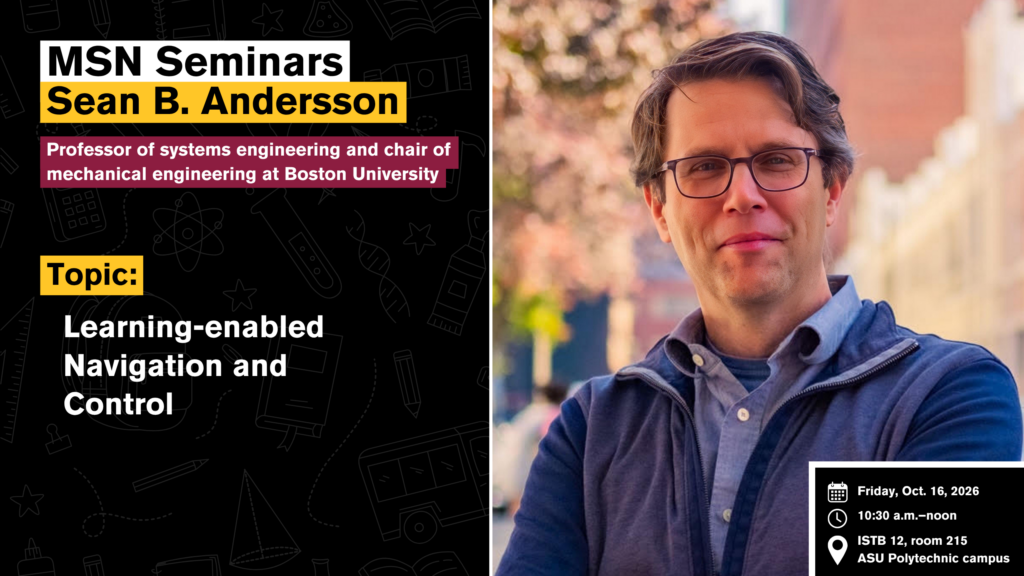
Attend a seminar on learning-enabled navigation and control, Oct. 16
About
Sean B. Andersson earned a bachelor’s degree in applied and engineering physics from Cornell University in 1994, a master’s degree in mechanical engineering from Stanford University in 1995 and a doctoral degree in electrical and computer engineering from the University of Maryland, College Park, in 2003.
Before pursuing his doctoral degree, Andersson worked at AlliedSignal Aerospace and AeroVironment. After earning his doctorate, he worked as a lecturer in applied mathematics at Harvard University before joining Boston University in 2003.
Andersson is a professor and chair of mechanical engineering and a professor of systems engineering at Boston University. His research focuses on systems and control theory with applications in biophysics and robotics.
Abstract
Learning-based methods offer exciting possibilities for robotics and control, but the safety-critical nature of robotic systems and their tasks demands that these methods be applied with care. This challenge is particularly acute for resource-constrained robots, where limited sensing, computation and energy leave little margin for error.
In this talk, Sean B. Andersson will present recent work addressing these challenges on two fronts. First, he will introduce Box Map, a framework that uses prior knowledge of structured environments, encoded through a trained transformer network, to substantially reduce the sensing and computational demands of mapping unknown environments.
Second, Andersson will discuss a Lyapunov-based control framework with explicit safety constraints that provides certificates of safety and performance for learned controllers. He will first present the framework in a general setting and then demonstrate how it integrates with Box Map, creating a unified approach to safe and efficient autonomy under resource constraints.
Learning-enabled Navigation and Control seminar
Friday, Oct. 16, 2026
10:30 a.m.–noon
Interdisciplinary Science and Technology Building 12 (ITSB 12) room 215, Polytechnic campus [map]